Acoustic Modem
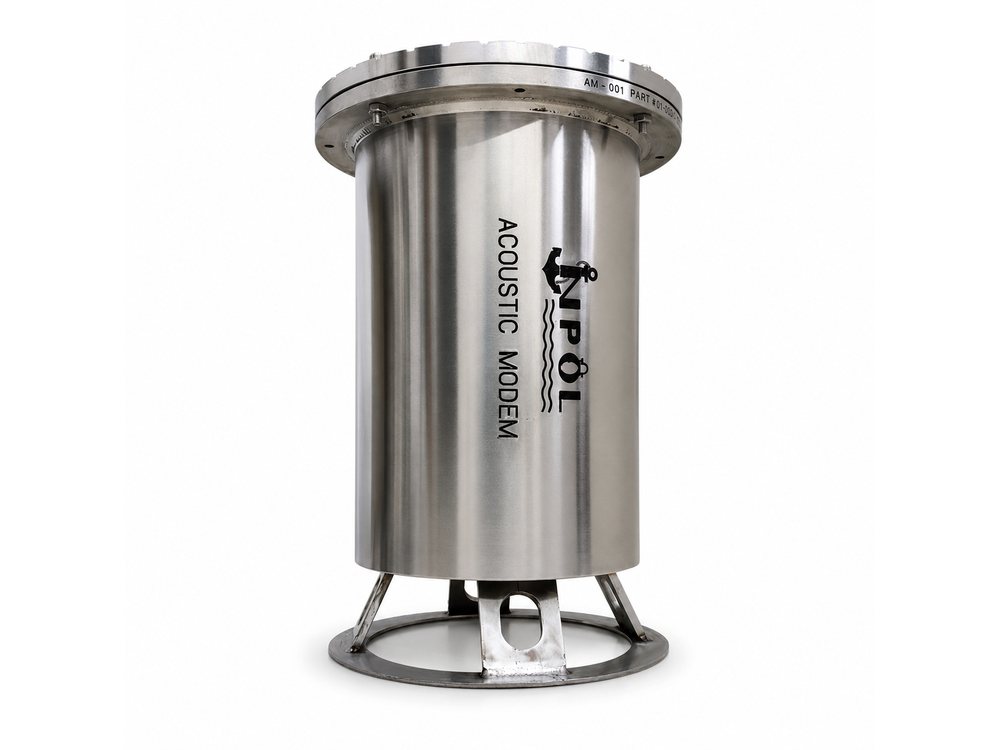
Fully embedded, software-defined underwater modem. Four-plus variants spanning 5–35 kHz with transmit power up to 100 W, interoperable with the JANUS open standard.
 Defence electronics portfolio
30 product systems · 4 capability domains
Designed & manufactured in India
Modular · scalable · interoperable
Radio does not travel underwater. Everything a submarine, an autonomous vehicle or a diver needs to send has to become sound — and every sound has to be recovered from an ocean that is louder, warmer and saltier than the waters most imported hardware was tuned for.
Ruggedised electronics, embedded firmware and signal processing — the undersea communications and sensing hardware at the centre of the portfolio.
Fully embedded, software-defined underwater modem. Four-plus variants spanning 5–35 kHz with transmit power up to 100 W, interoperable with the JANUS open standard.
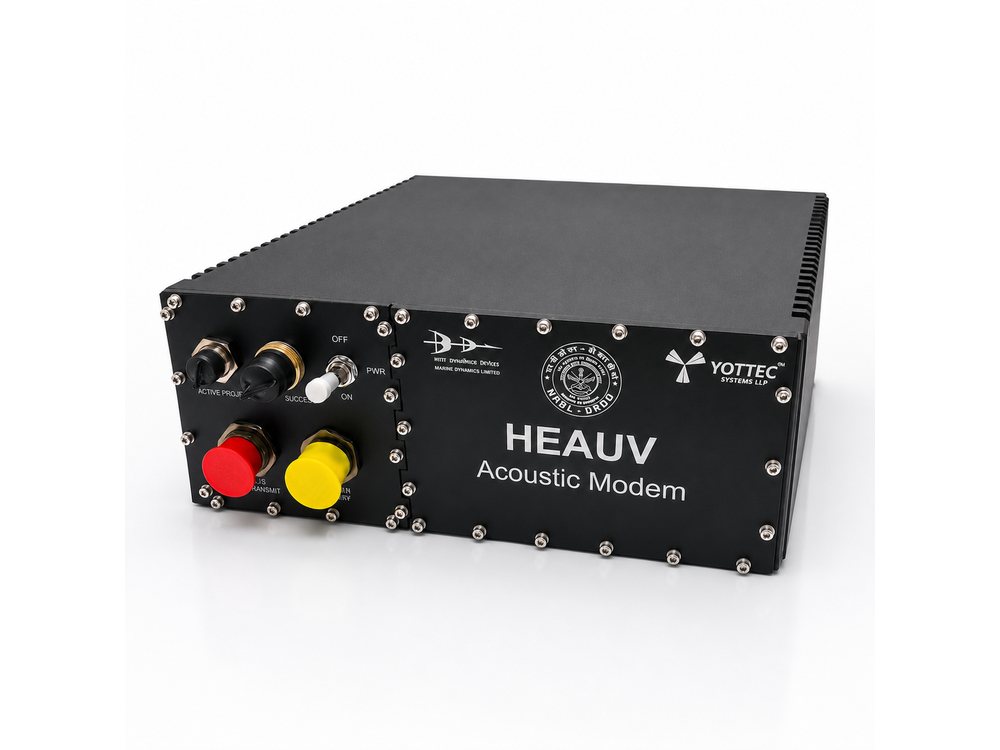
Compact, low-power modem for autonomous underwater vehicles, sized and powered for long-endurance unmanned platforms and multi-node coordination.
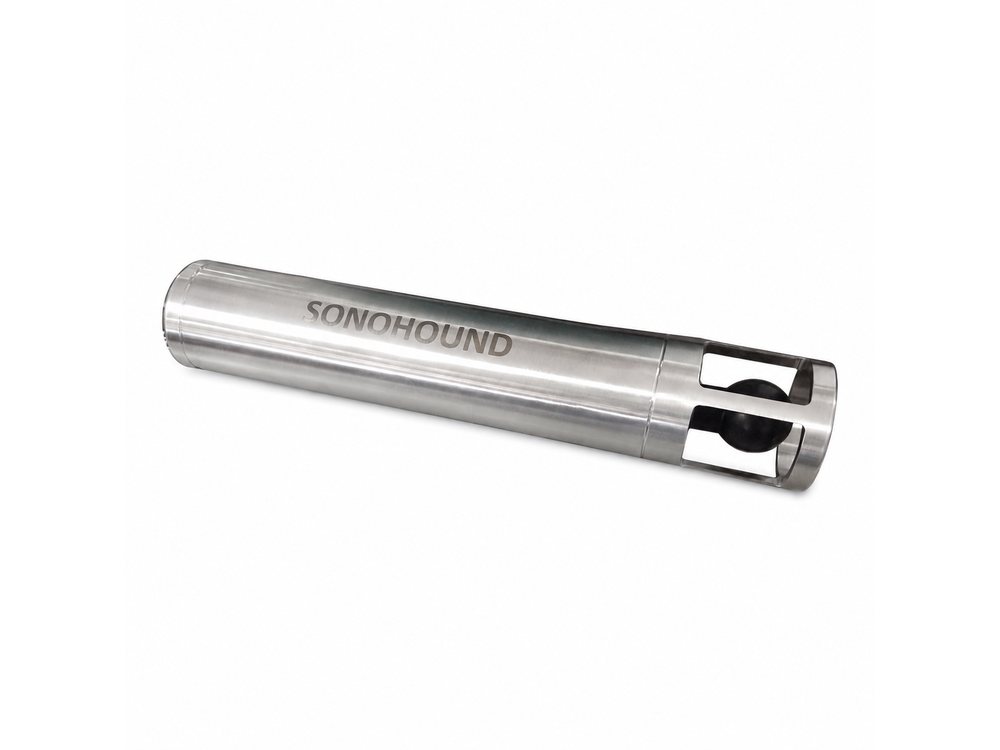
Long-duration recorder for ambient ocean noise surveys and acoustic range characterisation.
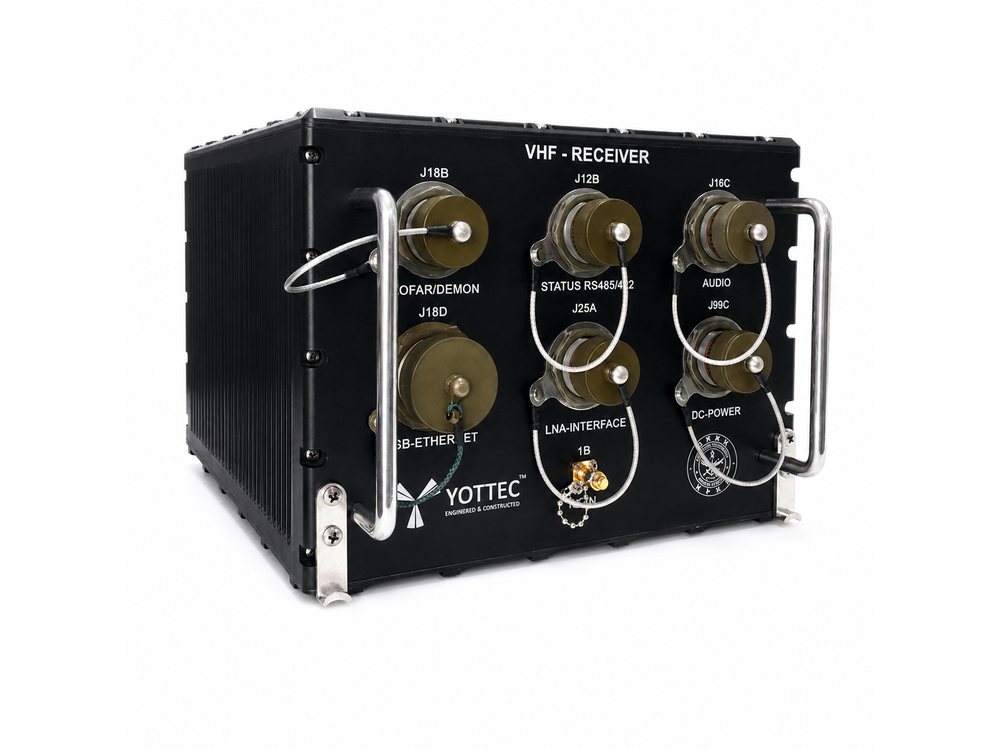
Purpose-built RF receive and transmit chains for telemetry and data relay in the maritime environment.
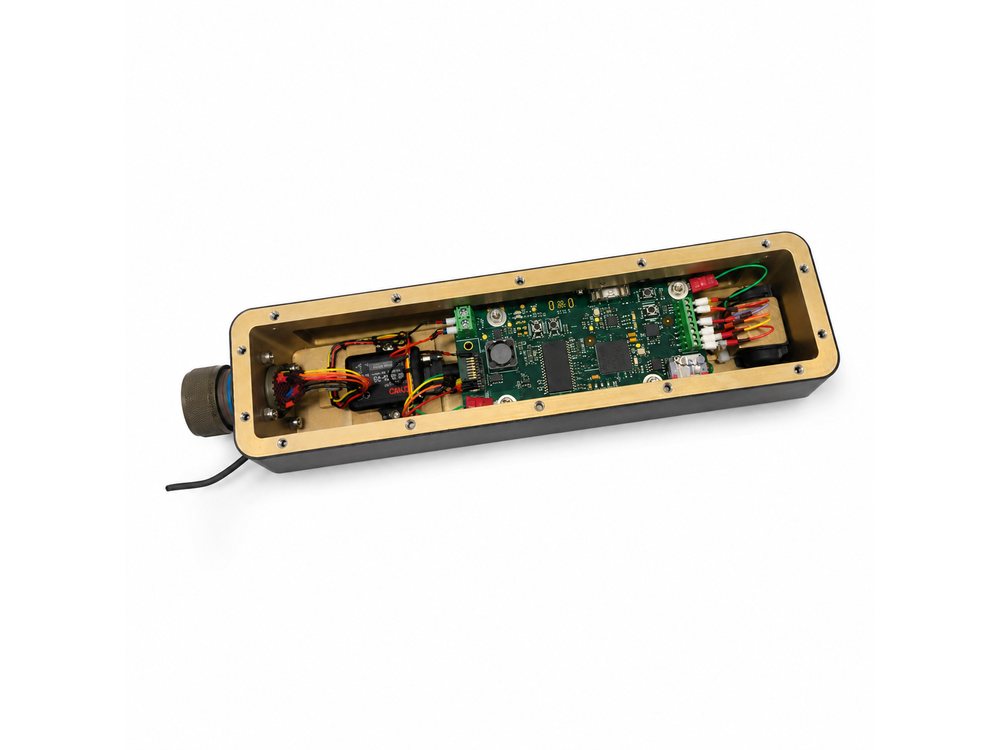
Ruggedised inertial data logger and attitude-heading reference for airborne, marine and underwater platforms.
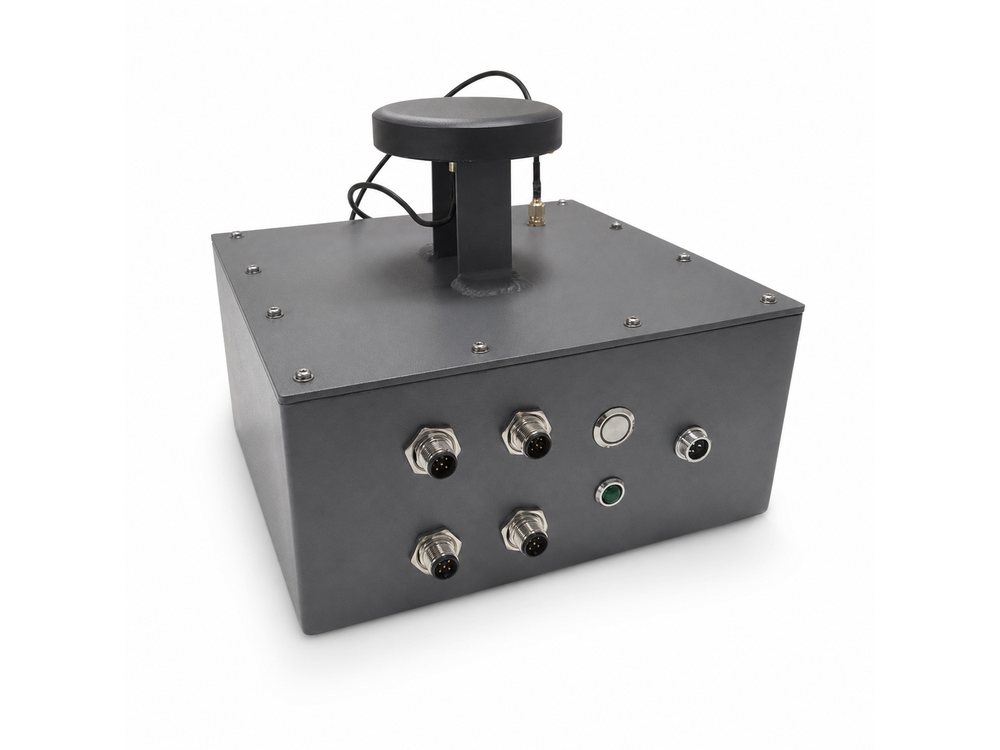
Low-power distributed sensing and processing nodes for instrumented field trials and networked sensor arrays.
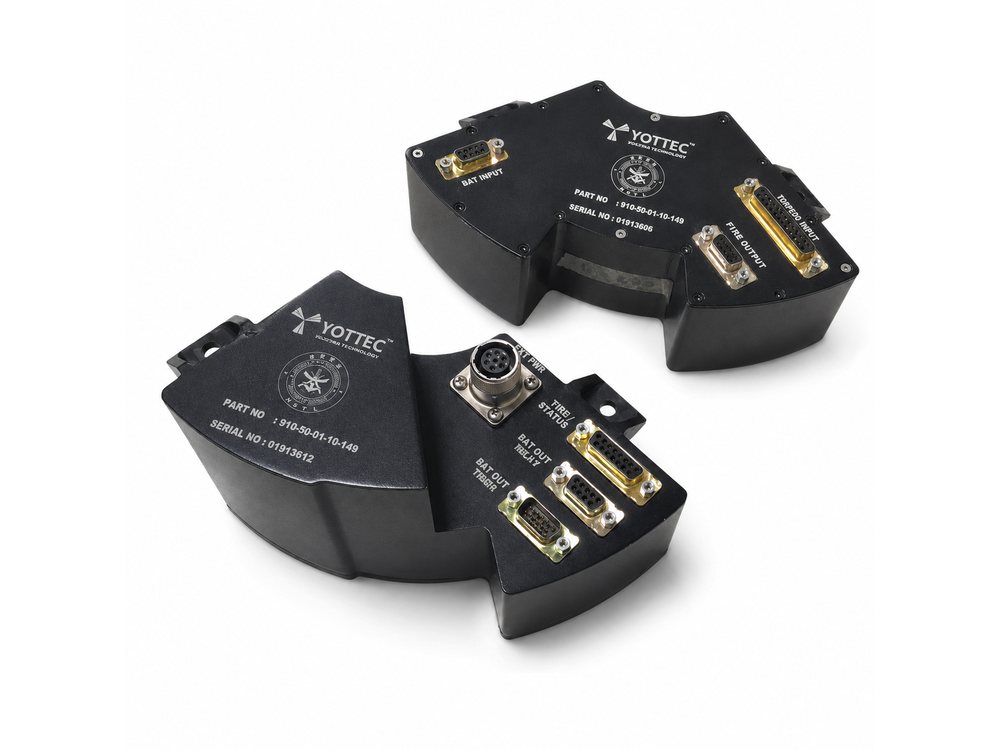
Precision electromechanical release assembly for underwater stores, qualified for the shock and immersion environment.
A forward post at 5,000 metres is supplied by road, mule or helicopter — all slow, all weather-dependent, all costly in risk. Autonomy changes that arithmetic, but only if the aircraft actually performs where the air is thin and the wind is not.
Airframes, flight electronics and autonomy designed together, and qualified against airworthiness standards rather than fair-weather demonstrations.
Flagship platform
Heavy Payload High-Altitude Do-Deca Copter
Heavy payload lift for elevated terrain and rugged operating zones. Programmable autonomous missions, centimetre-level landing accuracy and zero human intervention at the drop site — tested at 6,000 m at Khardung La, Ladakh.
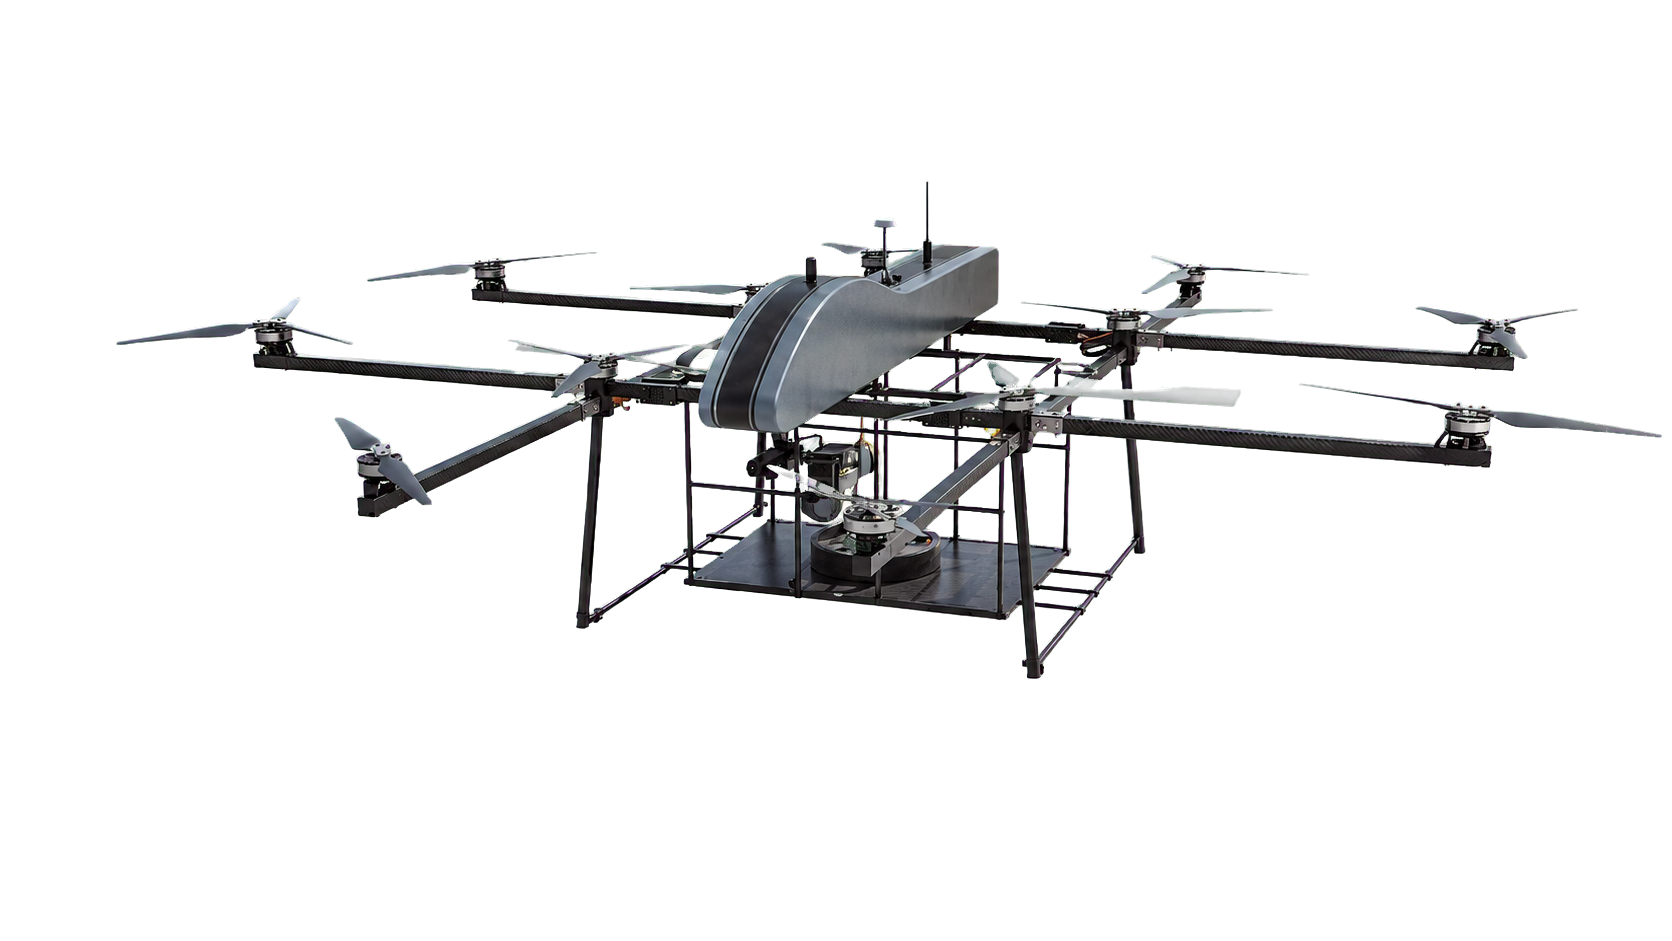
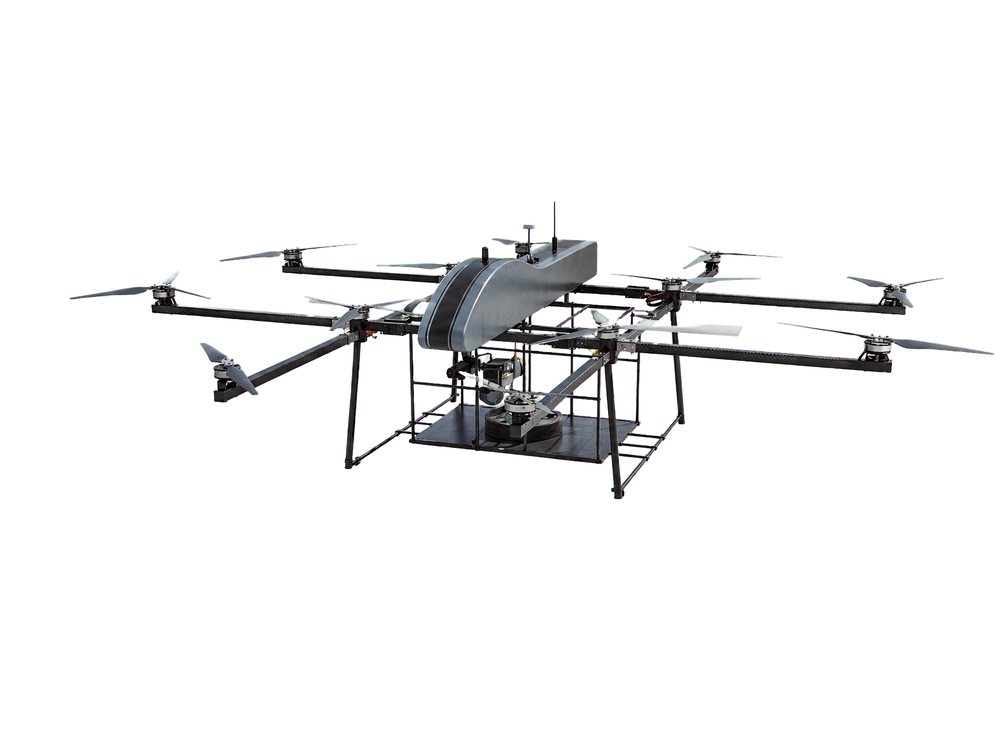
The MC-09. Twelve-rotor, all-electric logistics platform: 20 kg payload, 20 km range, operation to 6,000 m AMSL. Full specification above.
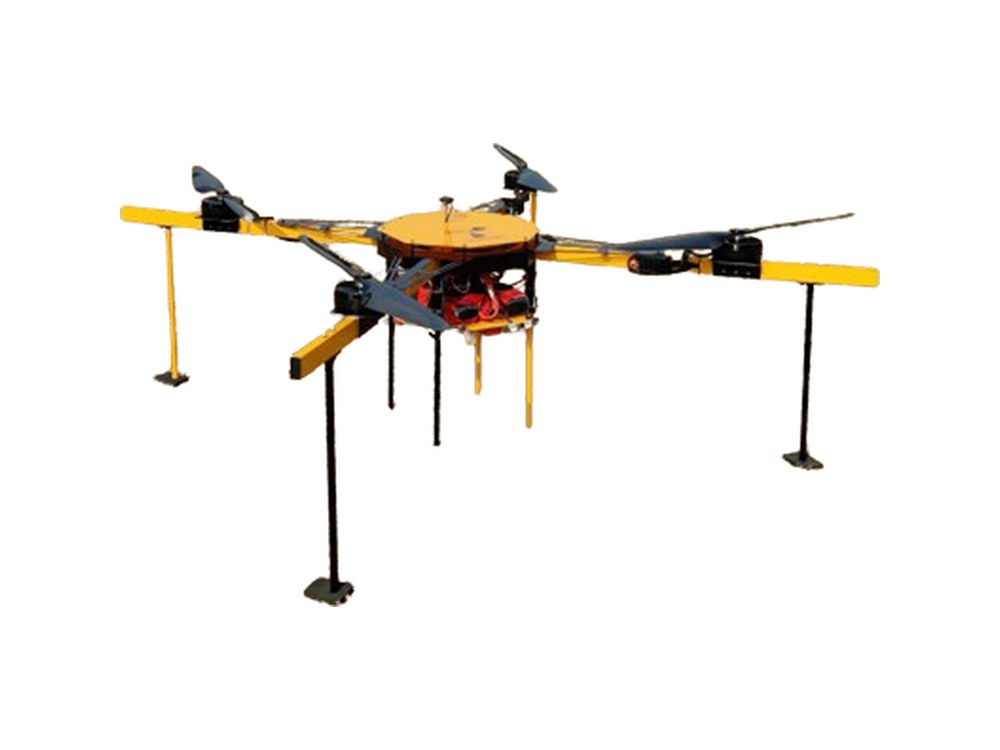
Four-rotor heavy-lift platform for supply, equipment movement and emergency transport.
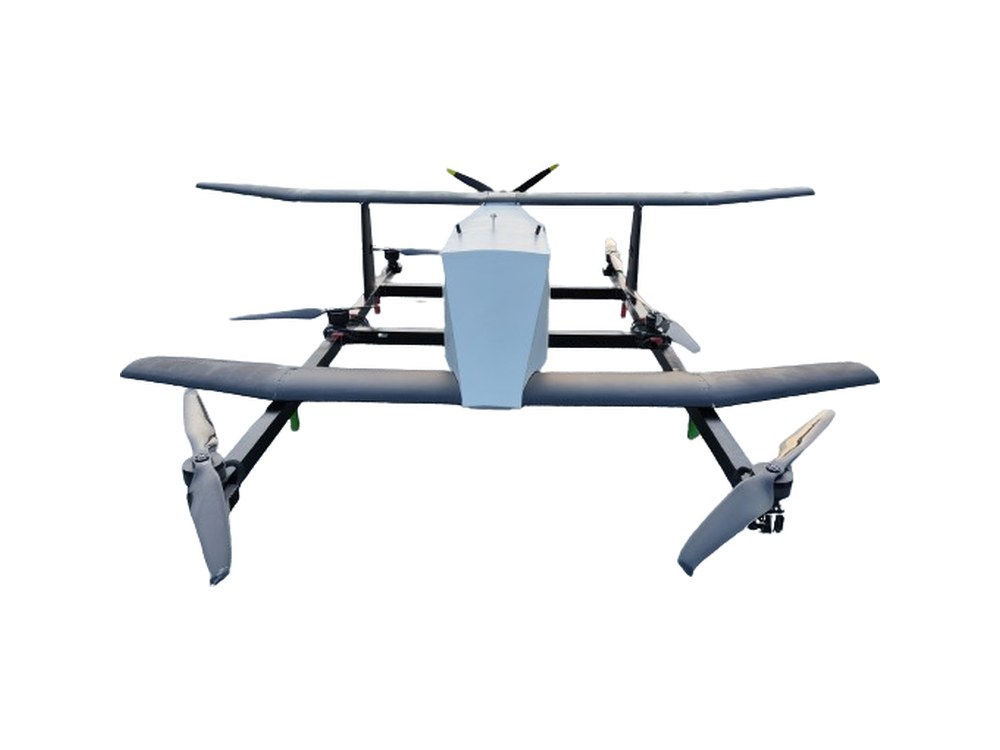
Fixed-wing VTOL combining vertical launch with long-range cruise efficiency for extended logistics legs.
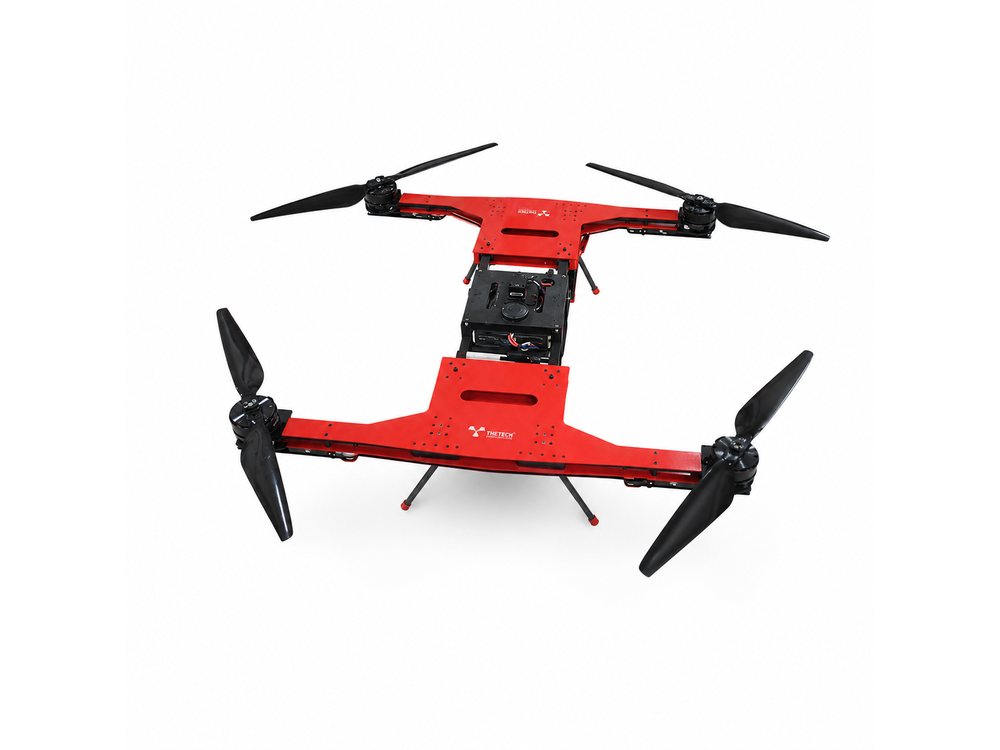
Mid-class multirotor for routine resupply, survey and instrumentation carriage.
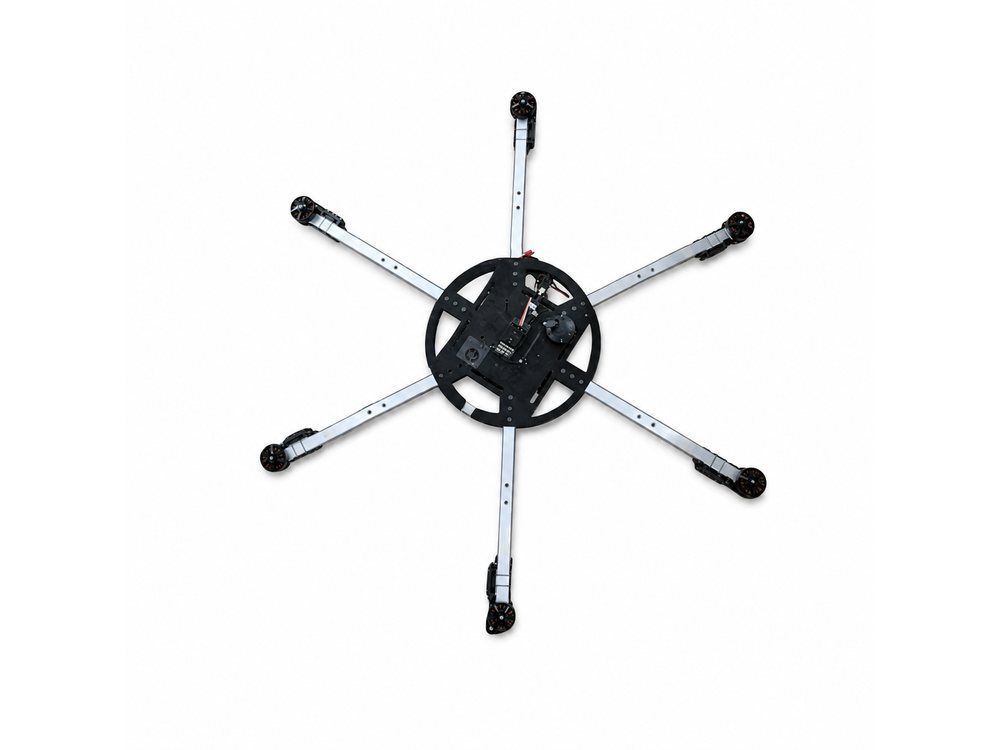
Six-rotor platform with redundant propulsion for sensitive payloads and confined operating areas.
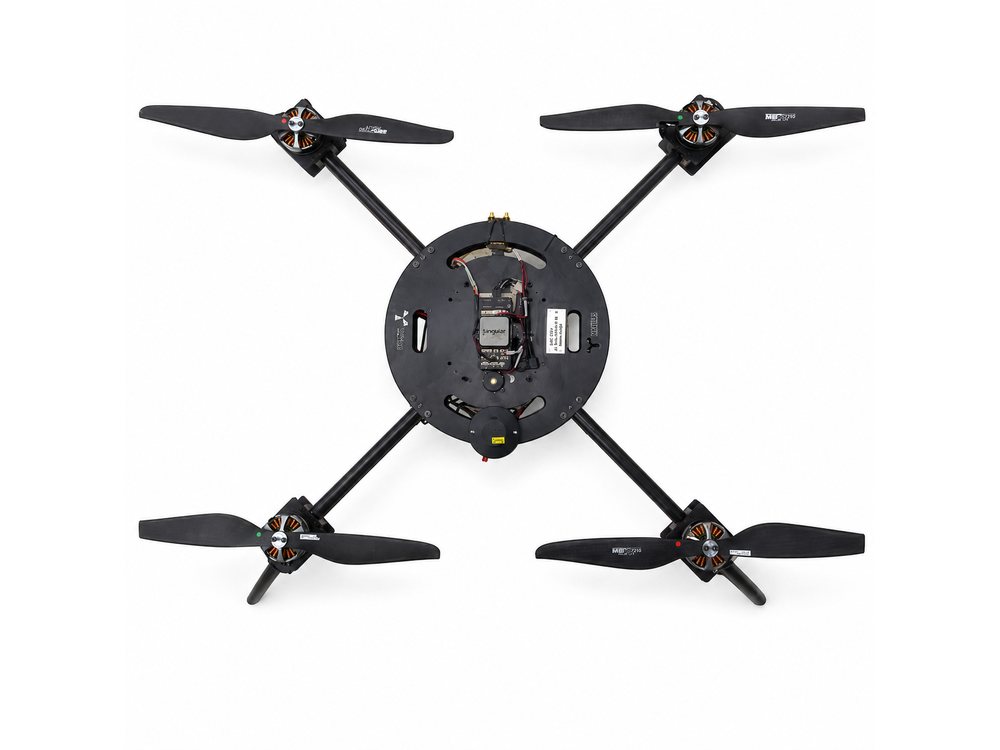
ISR multirotor carrying EO/IR and mission sensors with real-time downlink.
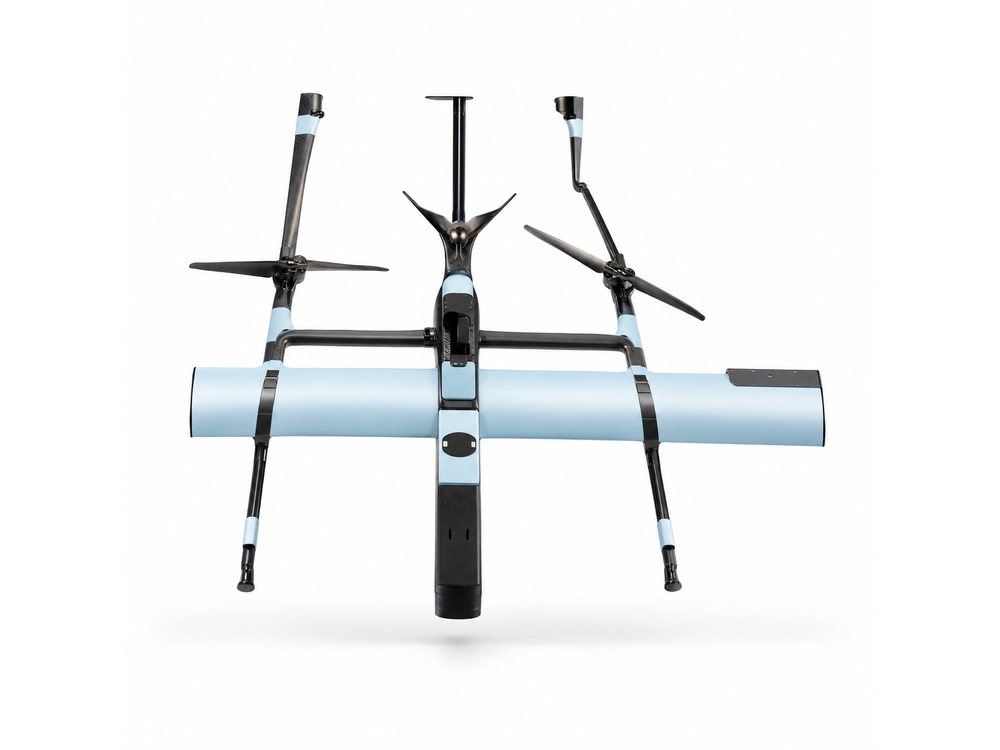
Long-endurance fixed-wing VTOL for wide-area persistent surveillance.
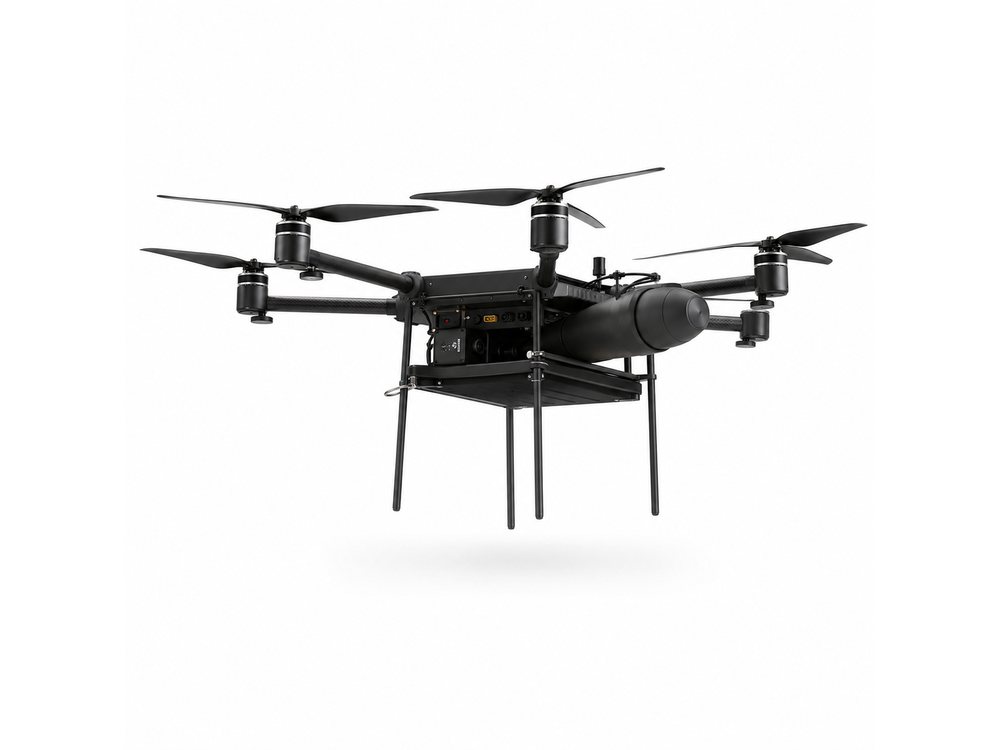
Loitering aerial system in the heavier payload class, recallable in flight, in multicopter, VTOL fixed-wing and canister-launched configurations.
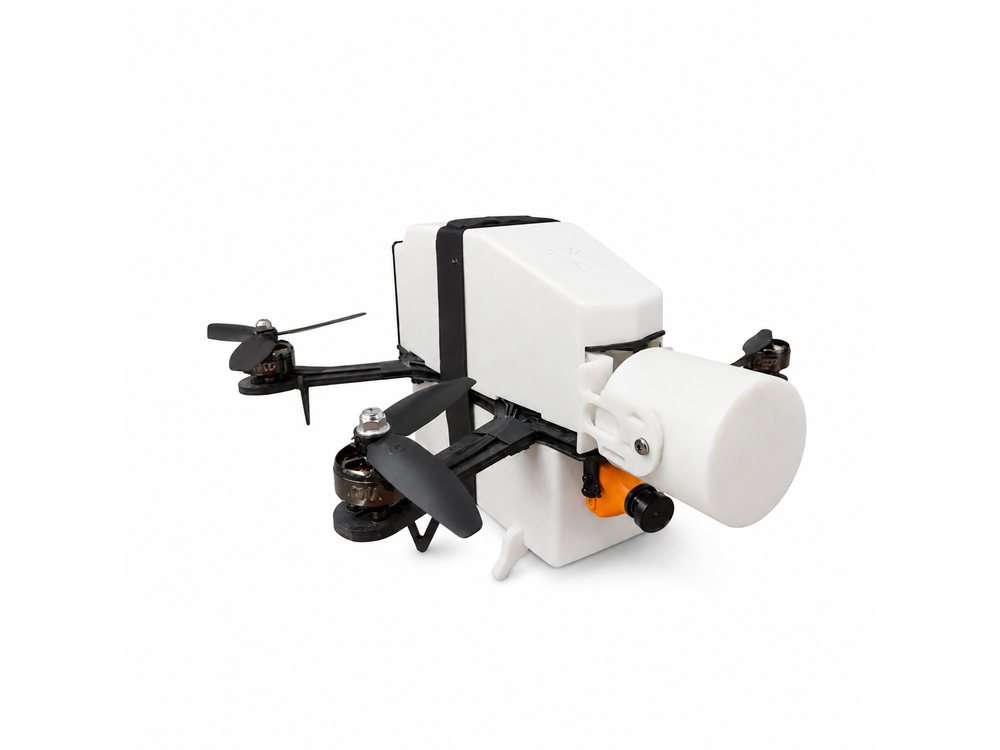
Loitering aerial system in the lighter payload class, spanning the 25 g to 5 kg band, recallable in flight.
Nothing enters service until it has been proved. Since 2008 Yottec has built the rigs, benches and instrumentation that other people’s systems are qualified on — which is why our own hardware arrives already knowing how it will be tested.
Qualification infrastructure: test beds, calibration facilities, checkout systems and integration benches, designed around each programme’s real constraints.
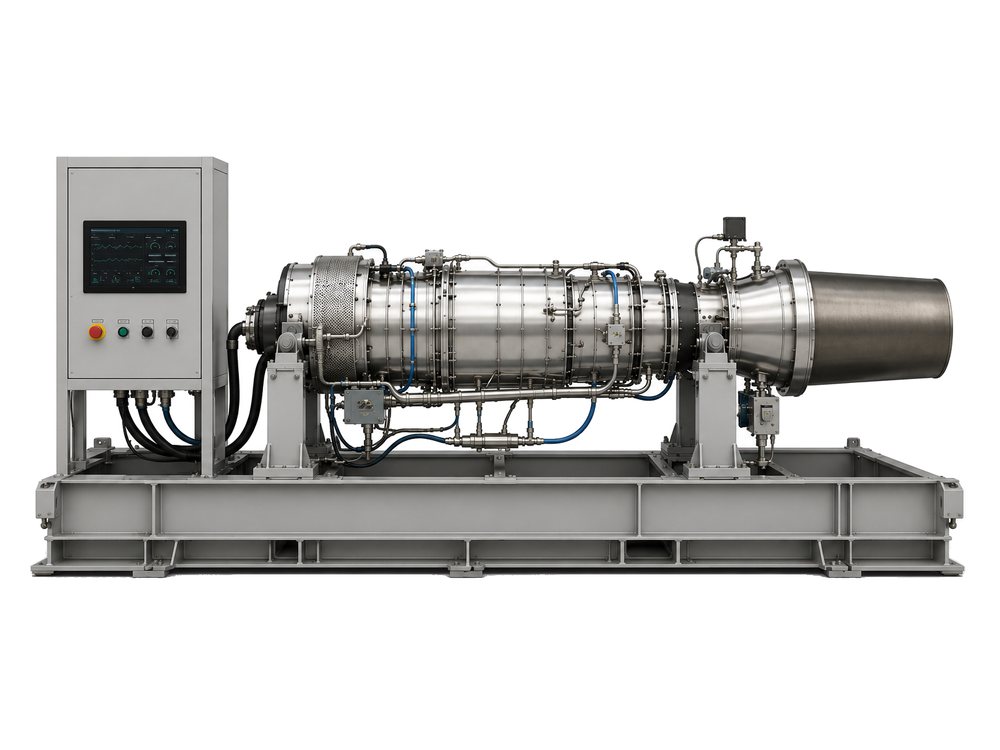
Instrumented test beds for engine performance characterisation and endurance testing.
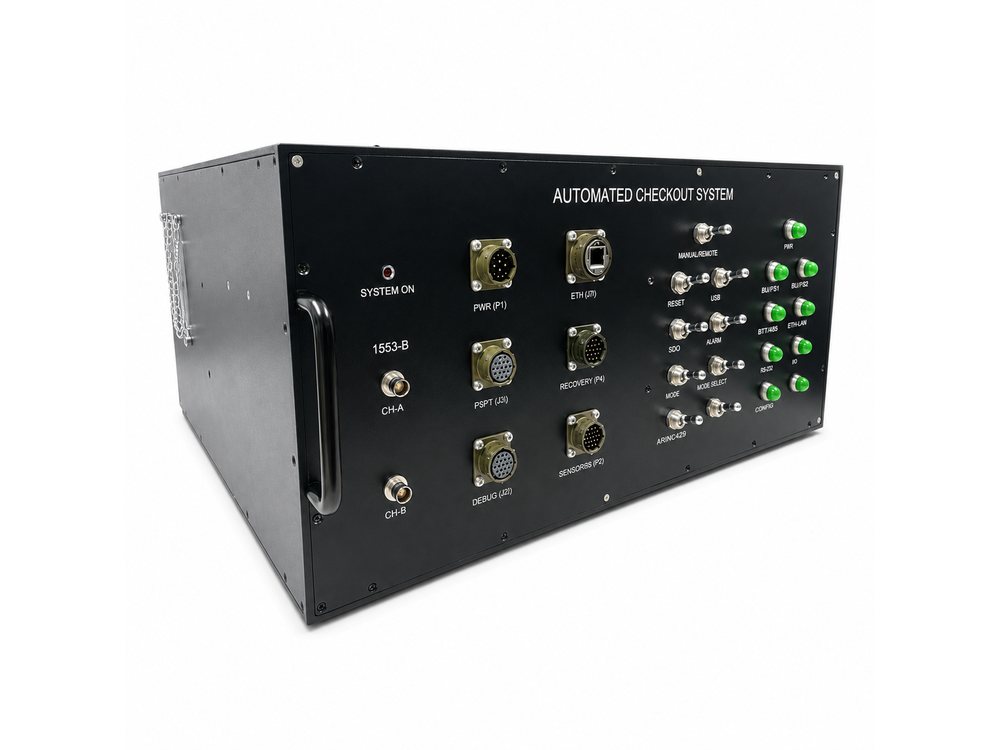
Automated functional checkout and acceptance testing for complex launch and flight subsystems.
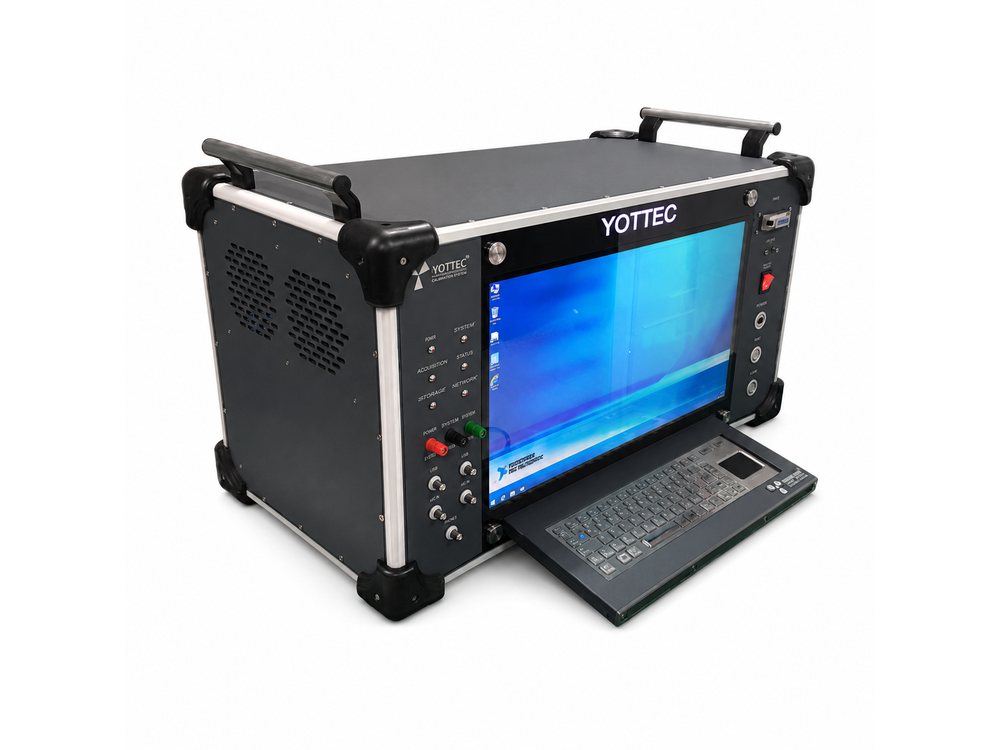
Turnkey calibration facility built to the IEC 60565 method for characterising hydrophones and projectors.
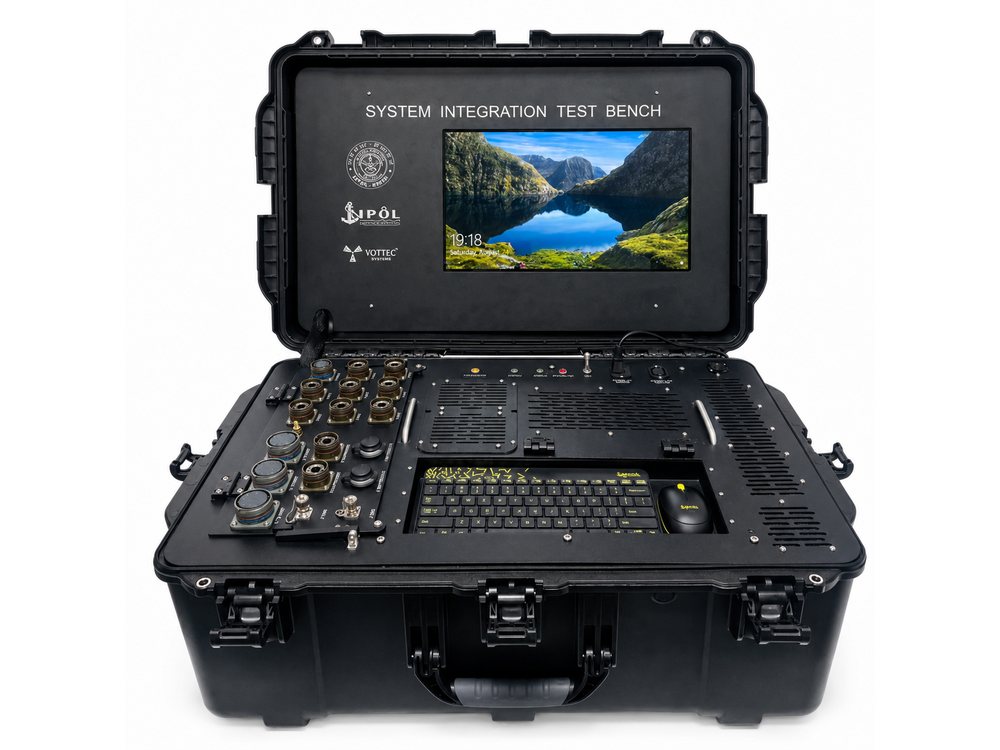
Full system-level bench for integrating, stimulating and validating sonar and acoustic subsystems before sea trials.
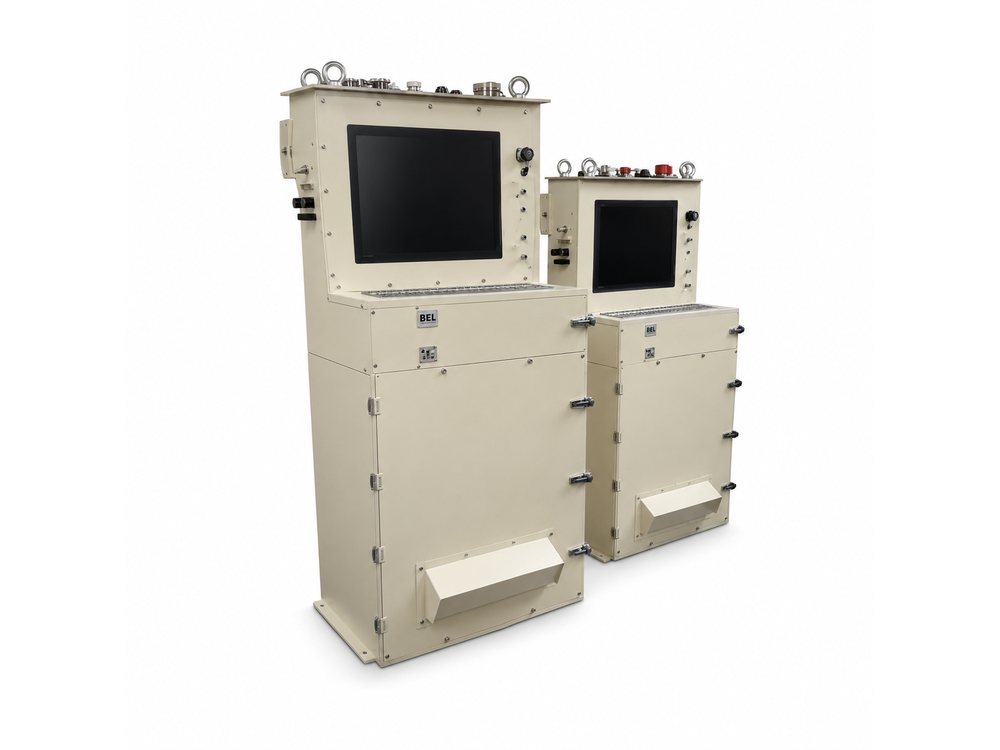
In-situ diagnostics for installed sonar arrays — award-winning, and designed to catch degradation before a mission does.
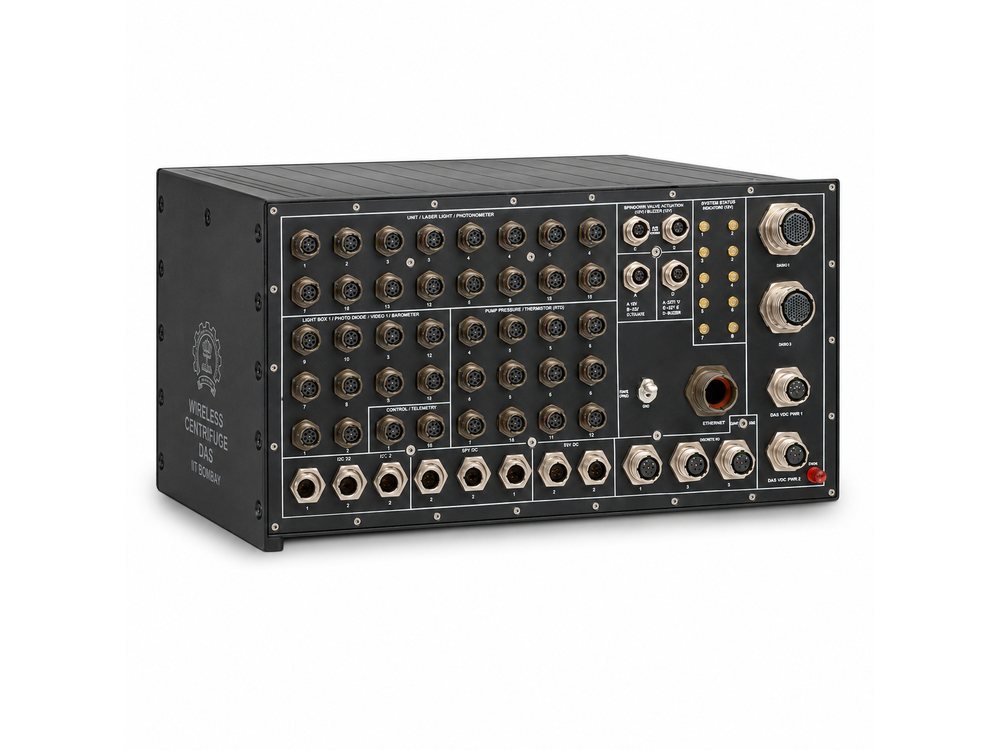
Wireless data acquisition for rotating and centrifuge environments where cabling cannot survive.
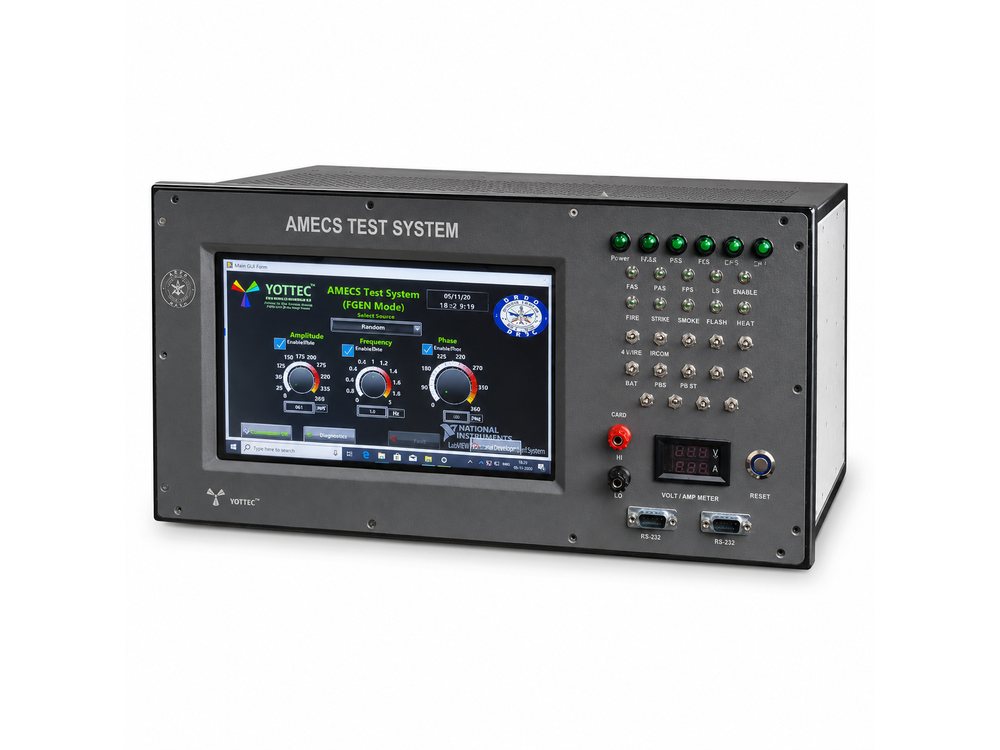
Instrumented rig for the safe test, measurement and evaluation of underwater stores.
Precision motion is where mechanical design, control theory and metrology stop being separate disciplines. A rate table that is accurate to a tenth of a degree is a mechanical problem, a servo problem and a measurement problem at the same time.
Servo-controlled motion, positioning and environmental simulation platforms — precise, repeatable and built to hold calibration.
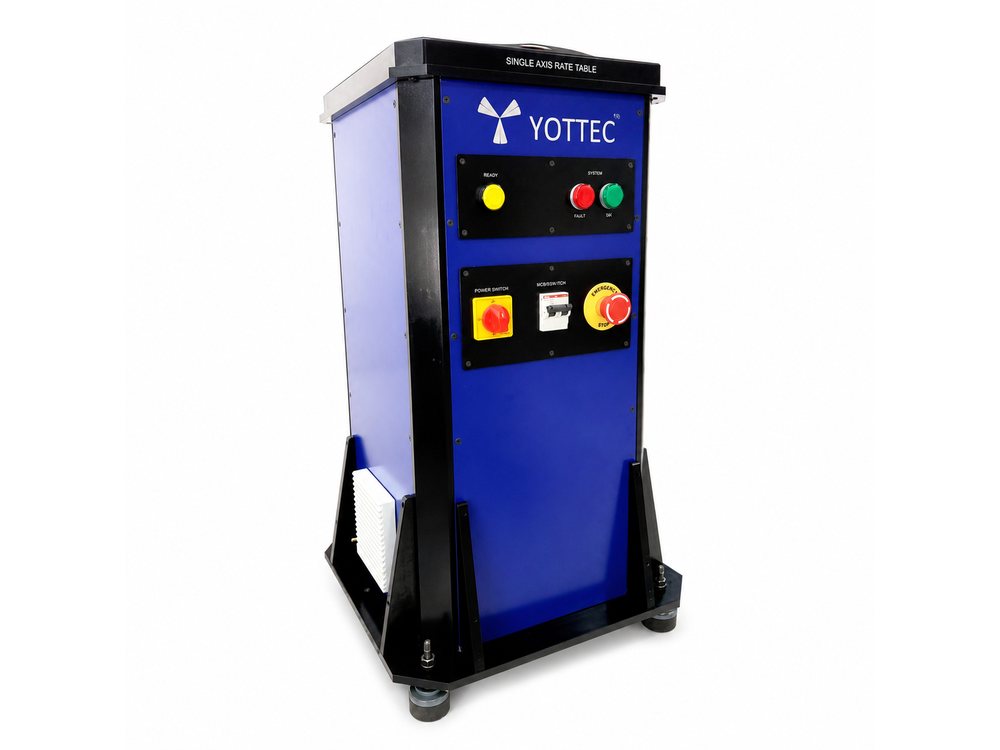
Single-axis precision rate table for gyro, IMU and sensor characterisation and calibration.
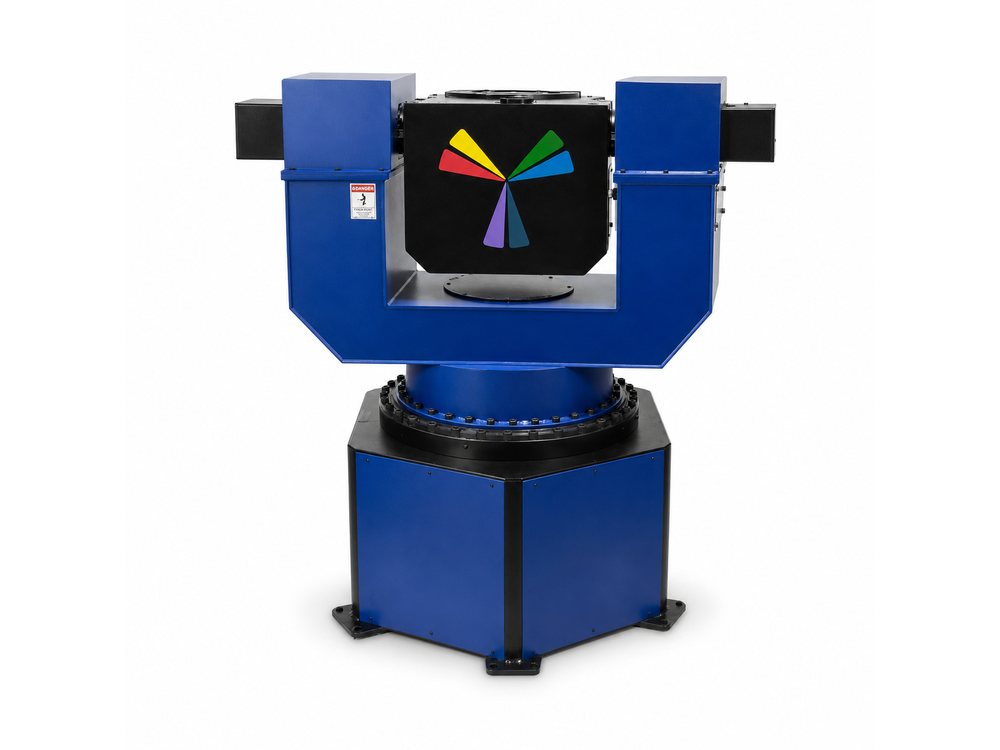
Servo-controlled inertial test table delivering precise rate, position and acceleration profiles across three axes.
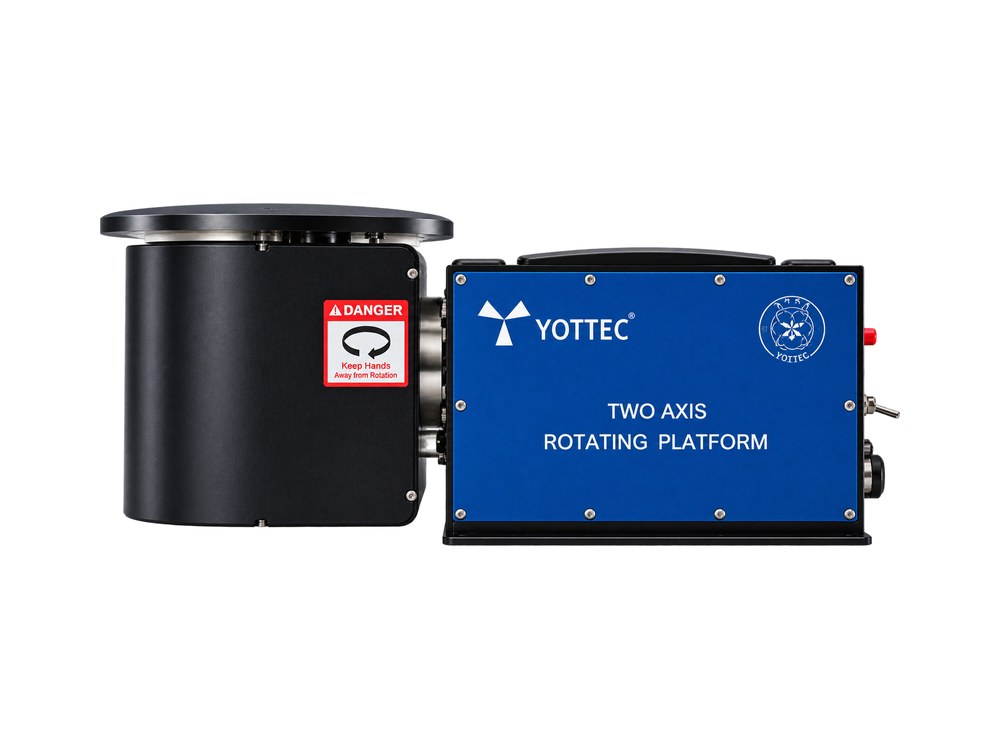
Azimuth-and-elevation positioning with slip-ring continuous rotation, for antenna, radome and sensor testing.
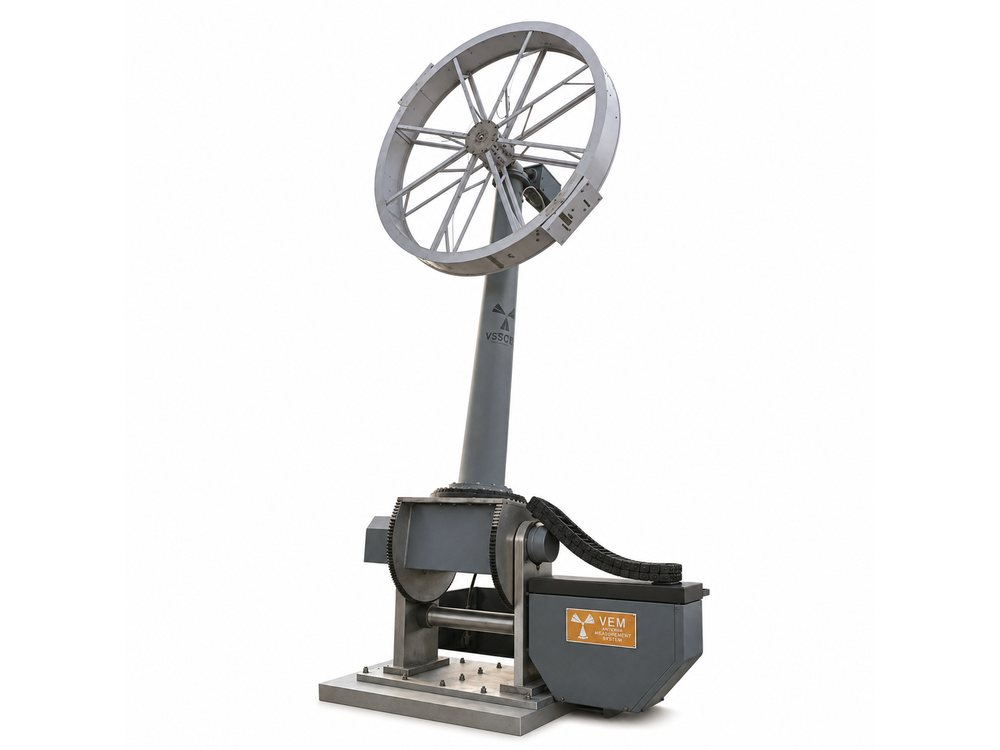
Integrated positioning and acquisition for antenna pattern, radome and telemetry measurement.
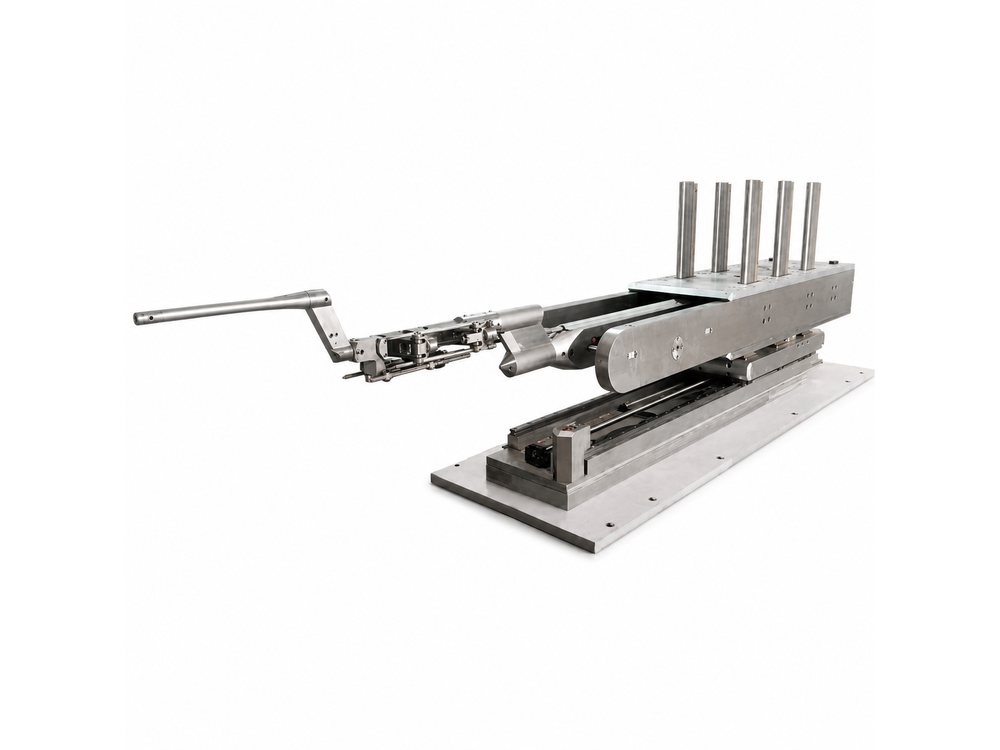
Purpose-built rig for controlled grid-referenced trajectory measurement and evaluation.
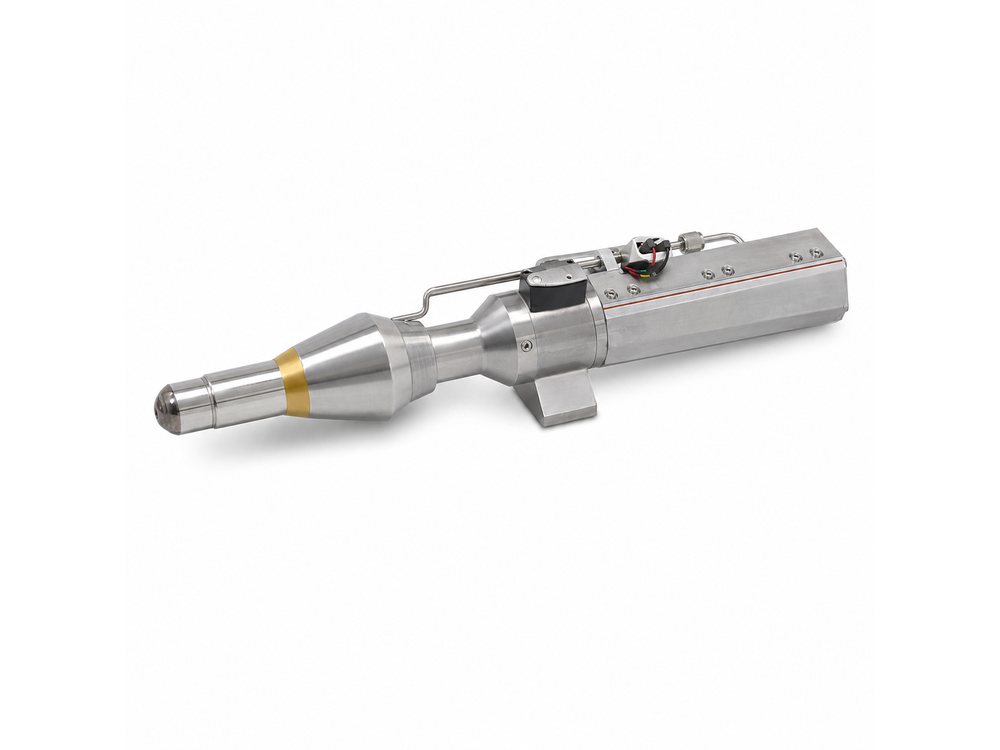
Precision gas mass-flow metering and control for test facility and propulsion applications.
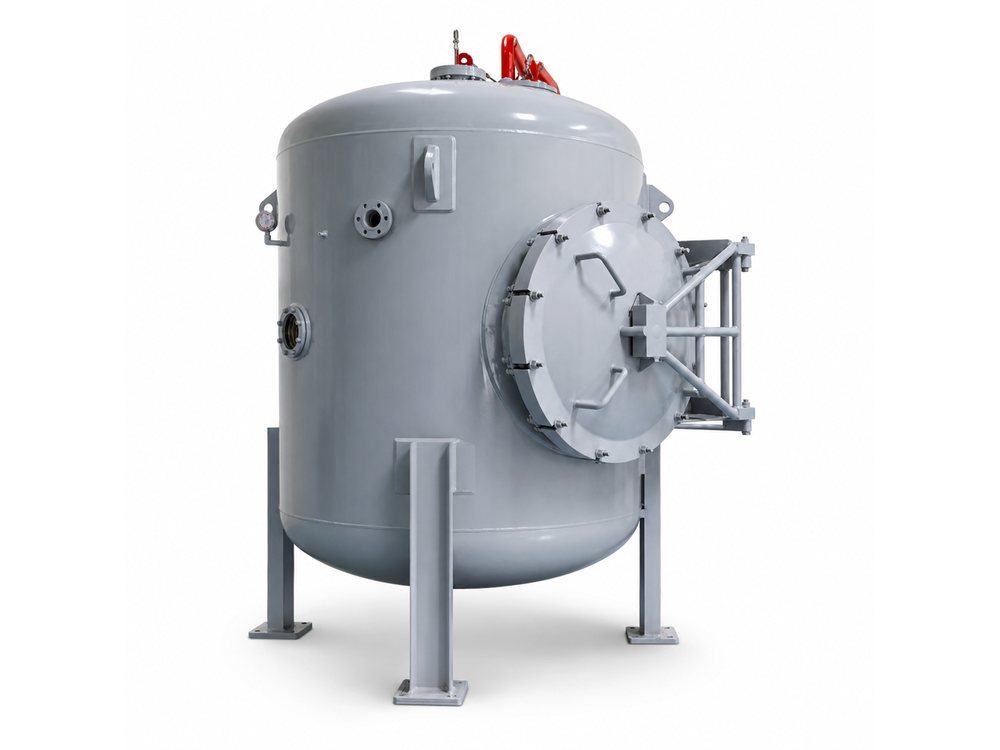
Pressure-cycling chamber for qualifying underwater assemblies against depth, sealing and immersion requirements.
Configurations, interfaces, frequency bands, payloads and environmental ratings are routinely tailored to programme requirements. Detailed specifications and datasheets are available on request.
Next step
That is usually where our work starts. Tell us the requirement and the environment, and we will tell you what is realistic.